fig4
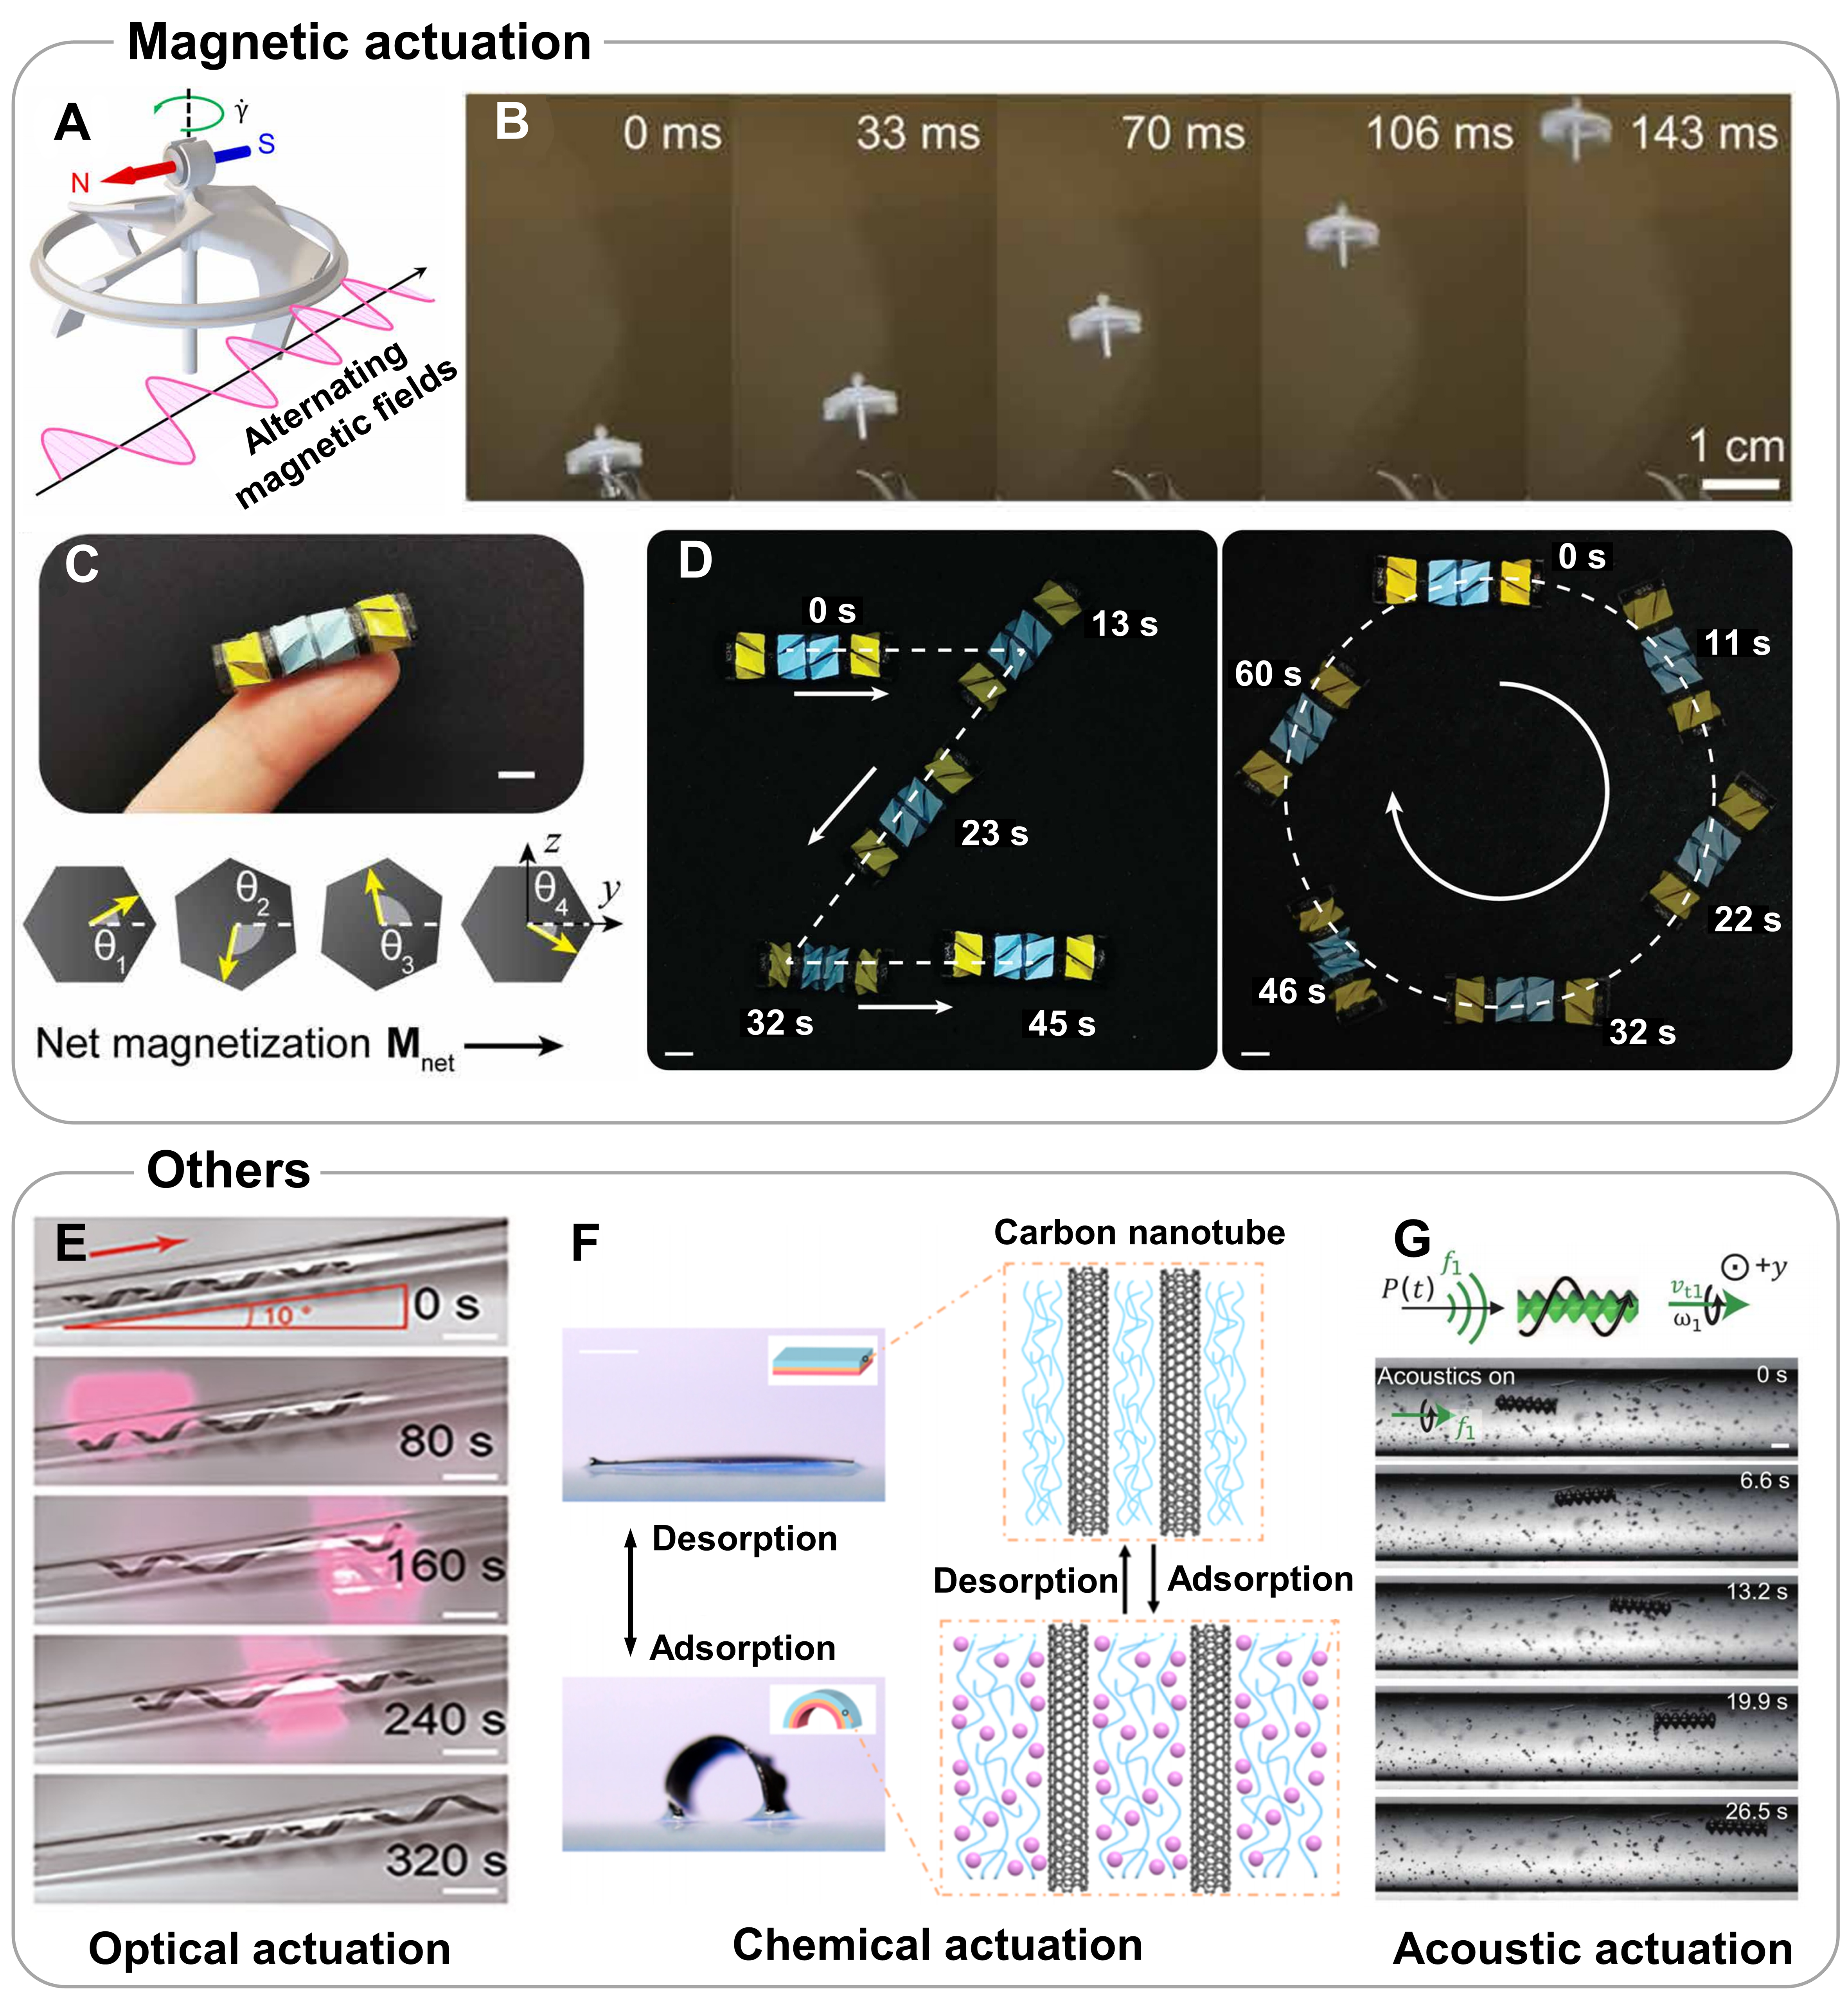
Figure 4. Representative untethered actuation technologies in soft robotics. (A) Working principle of the untethered subcentimeter-scale flying robot; (B) Optical images for the sustained upward flights. (A) and (B) were adapted from Ref.[66], under CC BY-NC 4.0 license; (C) Image of a fingertip holding the fabricated Kresling crawler and designed magnetization directions of the four magnetic plates for distributed torques, scale bars: 5 mm; (D) Steering and navigation of the Kresling crawler, scale bars: 5 mm. (C) and (D) were adapted from Ref.[67], under CC BY-NC 4.0 license; (E) Accordion crawling inside the inclined tube, scale bars: 10 mm. Adapted from Ref.[71], under CC BY 4.0 license; (F) Schematic of the actuating mechanism for strip-shaped actuators by reversible adsorption and desorption of solvents, scale bars: 2 mm. Adapted from Ref.[76], under CC BY 4.0 license; (G) Translational motion of the microrobot in a circular microchannel, scale bars: 100 μm. Adapted from Ref.[81], under CC BY-NC 4.0 license.